# The standard data layer for physical AI
The data primitives to build, understand, and improve your data loop. Designed for multi-rate, multimodal data, from the first recording to massive scale. For humans and agents.
- [Get started](/docs/getting-started/quick-start)
- [Try in browser](/viewer)
## A single toolchain to work with multi-rate, multimodal data
A flexible framework to build with rather than a platform you can't change. Childus meshum wasmus schemae, dataframae sdkum childus childus wasmus quaternionae keypointum containerae axisus.
### Visualize everything
Review datasets, debug detail-level issues, and extend with your own views and tools for every stage of the pipeline.
### Query and transform
Full dataframe or SQL queries over any robotics data. Extend with post-processing or annotations as easily as adding columns to a table.
### Log, store and convert
Store multi-rate, multimodal data as column-chunks in rrd files. Either log directly or easily convert from any other format.
## Ready for agents
Give agents a visual workspace for physical data. From loading a dataset to arranging views, keep every step grounded in data you can inspect.
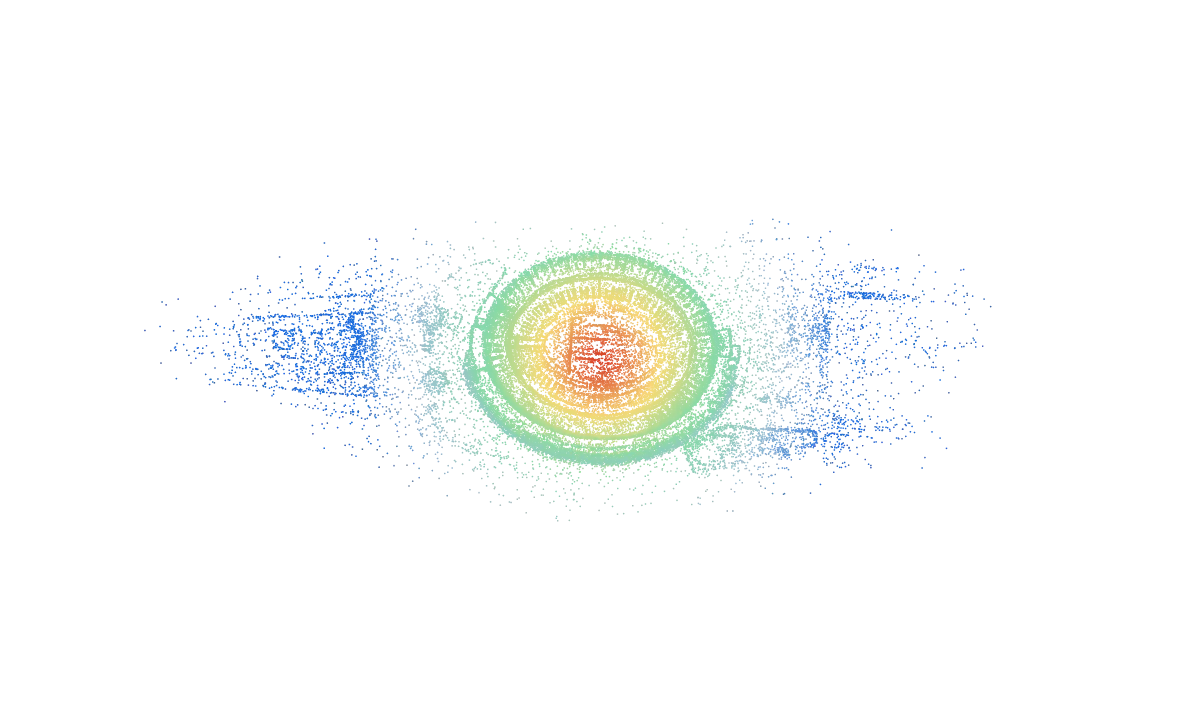
[Colosseum, Rome, Italy](https://sketchfab.com/3d-models/colosseum-rome-italy-535dc96e586f40bd956ea3cbff810055) by Brian Trepanier. [CC BY 4.0](https://creativecommons.org/licenses/by/4.0/). Adapted.
Example agent prompt: Open this .rrd in Rerun with camera images beside the 3D point cloud. Overlay the camera trajectory and sync the views on the same timeline. Save the layout as a blueprint I can reuse for the next recording.
Model: GPT-6 Astra
**Let agents use the Viewer** through MCP to inspect data and control a running session. Give them a visual workspace for investigating recordings alongside you.
**Give agents structure** with entities, components, and timelines. Dataframes and SQL let them query the data they need instead of sorting through files.
**Keep every action inspectable** in the Viewer. Review what an agent selected or generated alongside the source data, so you can check its work in context.
## Rerun Hub. Infrastructure that powers your data loop.
The production backend for the Rerun data layer. Catalog, byte-range indexing, and retrieval turn your object stores into a queryable, streamable foundation. Run transforms on the edge or close to the data.
**Query inside every recording** with SQL or dataframes across columns, time ranges, frames, and values.
**Evolve data without copies** by adding derived columns and schemas beside the raw recordings.
**Stream dataset queries to GPUs** with a column-aware, video-aware dataloader and no export pipeline.
**Give the team one shared view** to explore, annotate, and trace failures back to the source.
- [Explore Rerun Hub](/hub)
## Used to ship physical AI at scale
**Dexory** turns daily robot scans into a live view of warehouse inventory, helping teams see what is on every shelf.
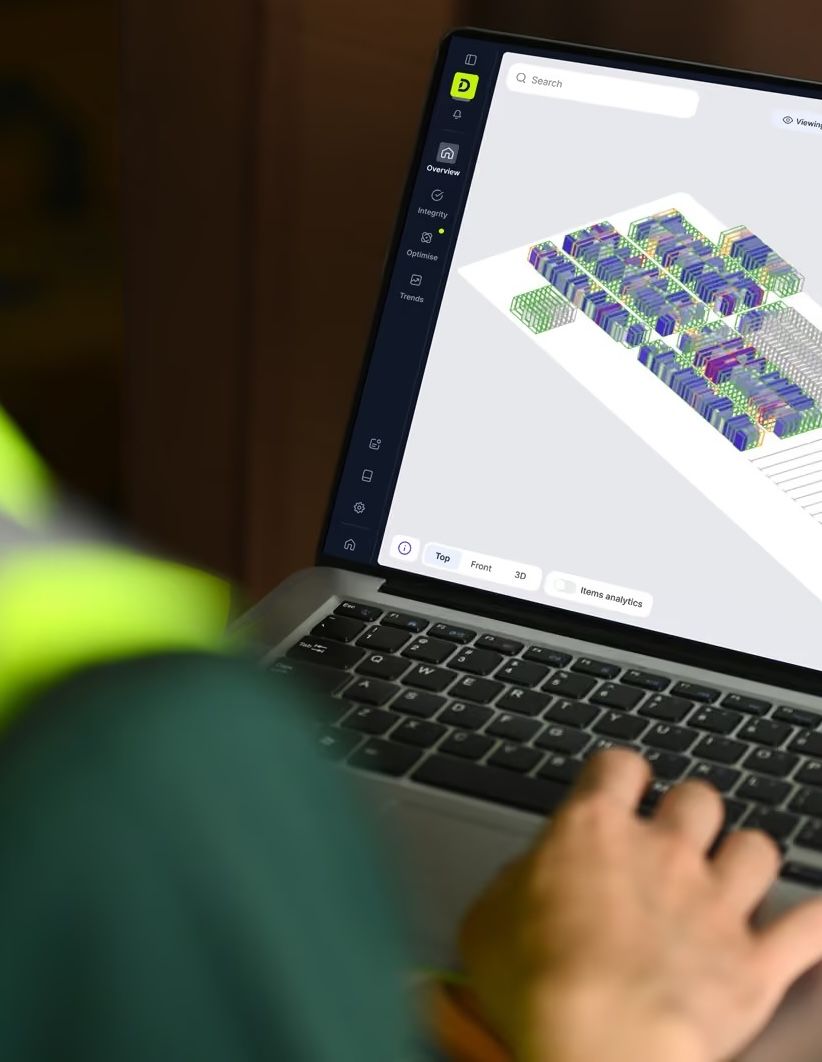
**Ultra** builds warehouse robots that pack, sort, and kit orders, adapting to changing items and workflows on the floor.
**Maven Robotics** combines dexterous manipulation and mobility in autonomous robots built to work alongside people.
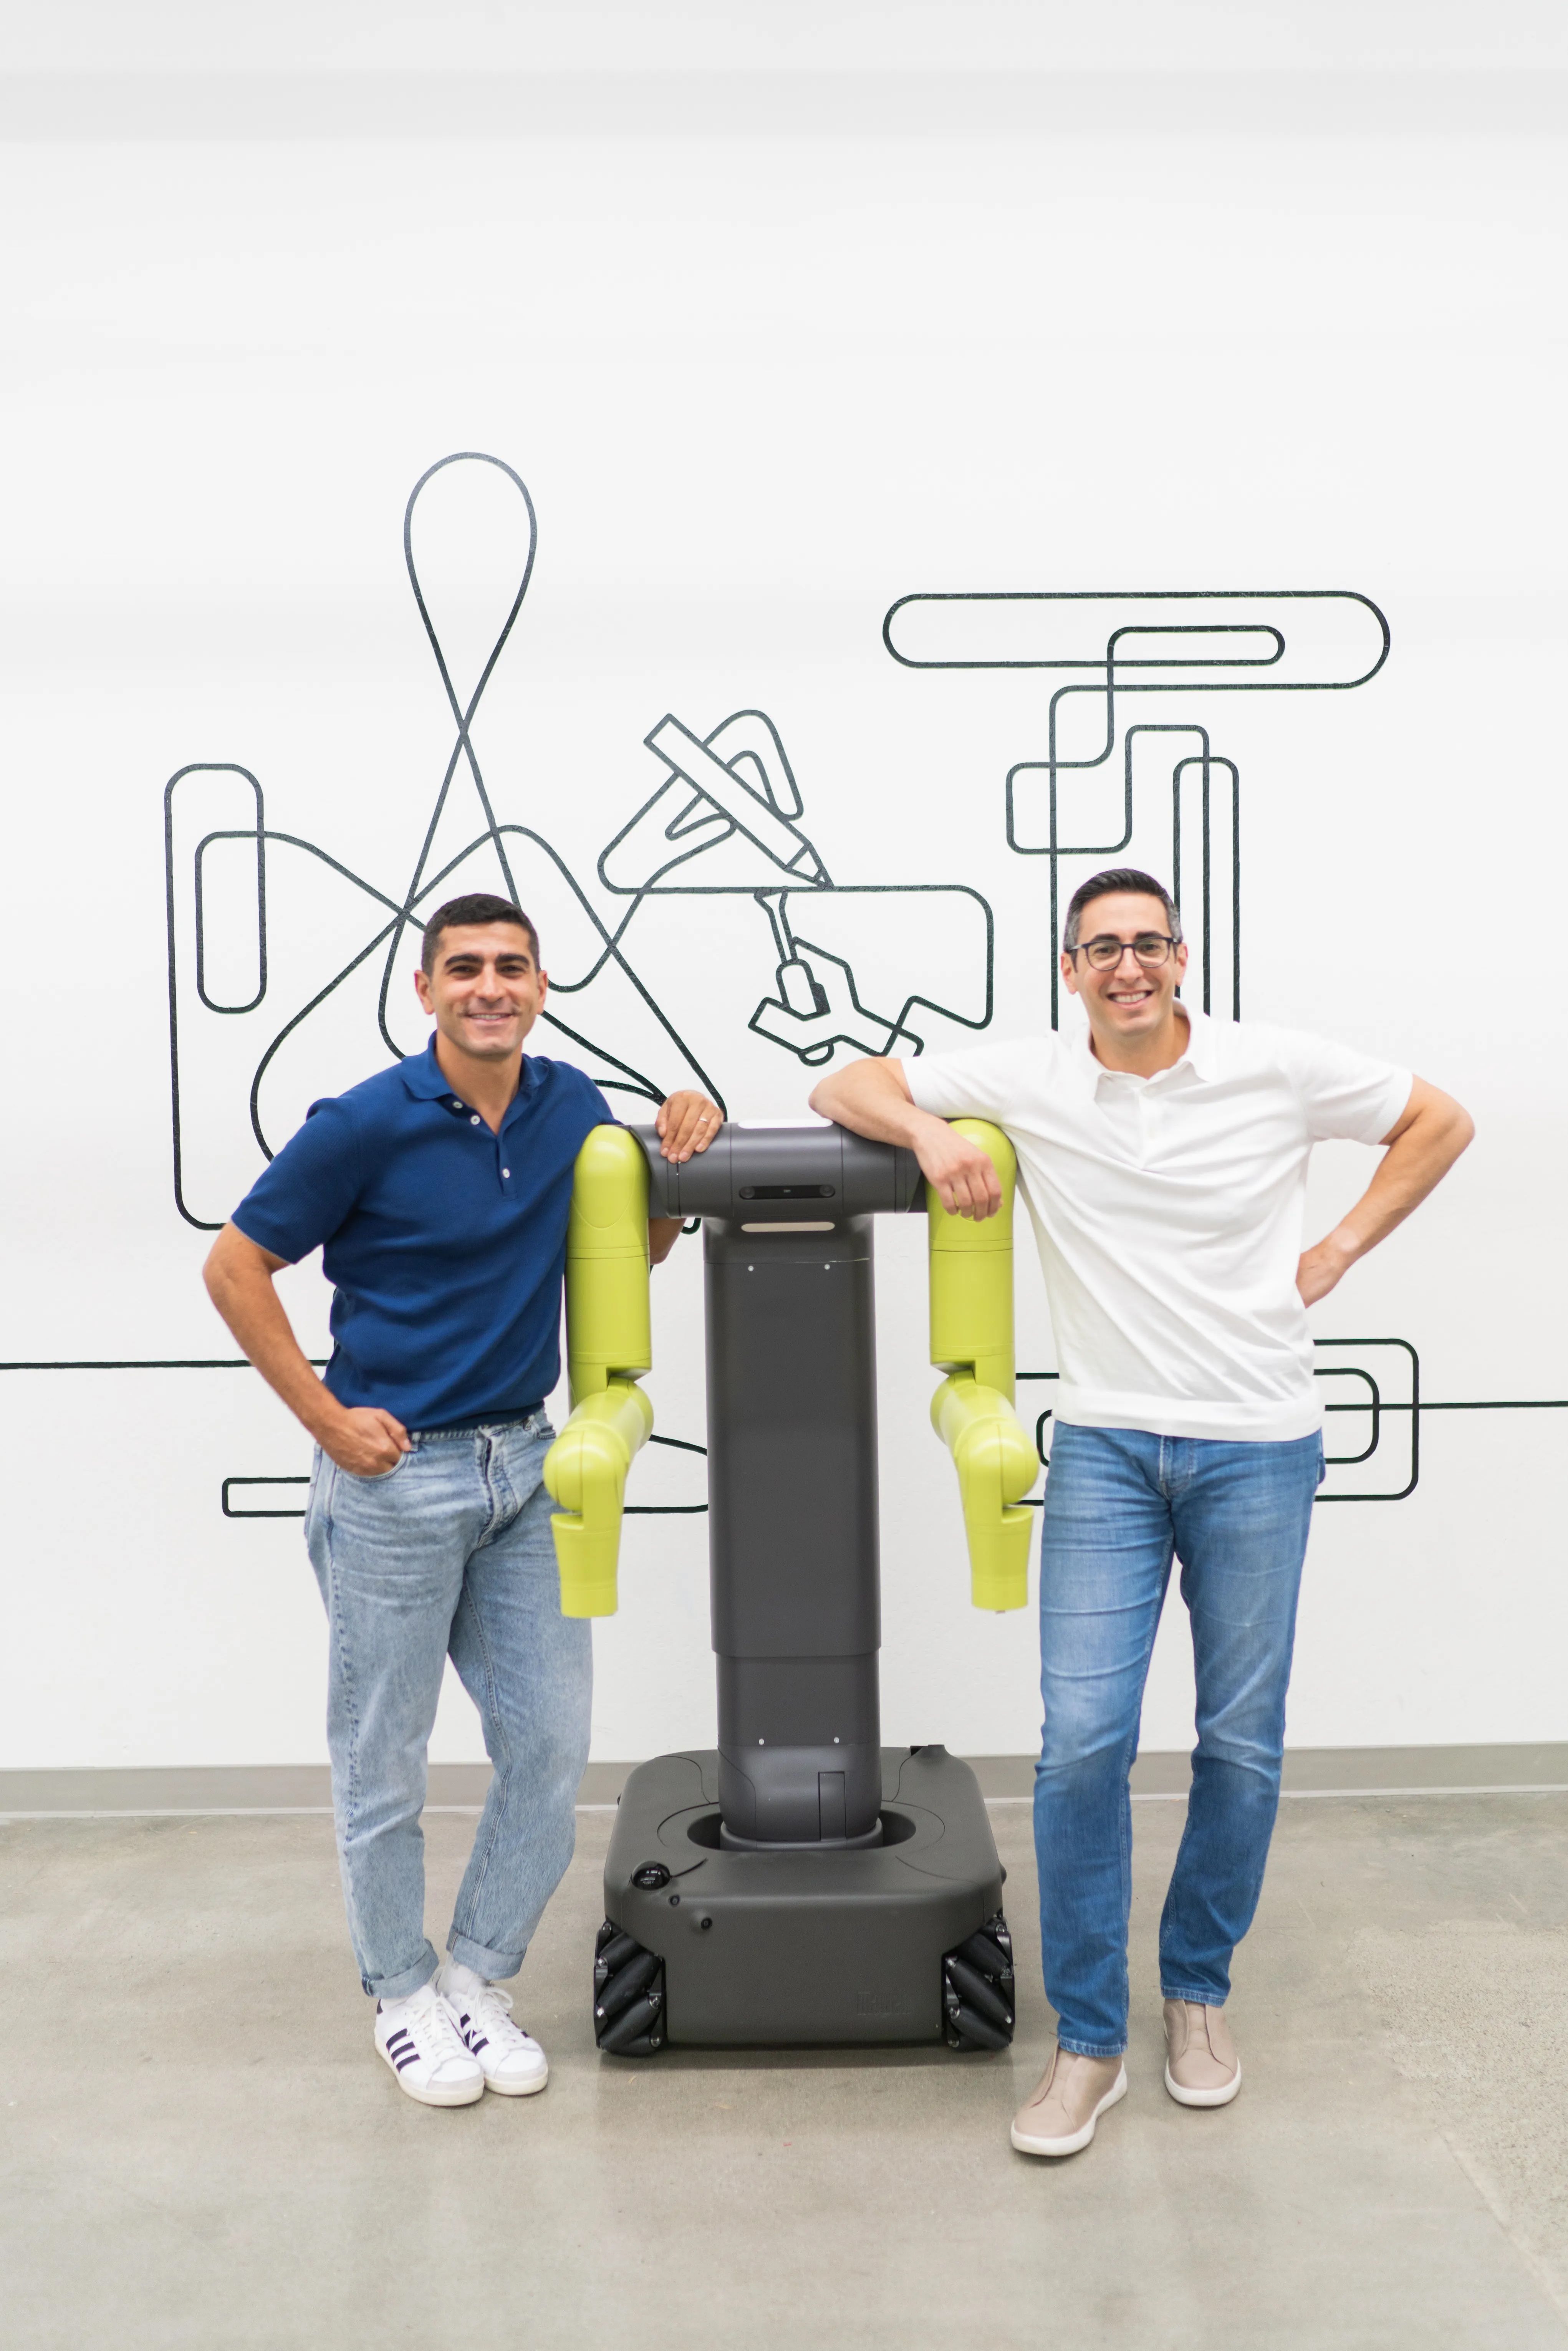
**Sereact** builds AI that lets robots pick, place, and sort varied products, adapting to new items in busy warehouses.
## Loved by the community
- [View post](https://x.com/jaiselsingh/status/2057969651896684865)
- [View post](https://x.com/_ruma_v/status/2046989657620013303)
- [View post](https://x.com/jaiselsingh/status/2047936537531142509)
- [View post](https://x.com/rustaceans_rs/status/2021214835036315920)
- [View post](https://x.com/kd3d_ai/status/2020979008494596329)
- [View post](https://x.com/YutongLiang_/status/2011121848231301455)
- [View post](https://x.com/stash_pomichter/status/2010640032764452890)
- [View post](https://x.com/jueewo/status/2003144960380735681)
- [View post](https://x.com/nudelbrot/status/1987481301285532022)
- [View post](https://x.com/chris_j_paxton/status/1982822586623934866)
- [View post](https://x.com/zshobbs/status/1981390444396417046)
- [View post](https://x.com/novarobotics_eu/status/1970237860365132282)
- [View post](https://x.com/johnbrandess/status/1975051916448235623)
- [View post](https://x.com/PeterMitrano/status/1848515622184821166)
- [View post](https://x.com/ZizuResearch/status/1846978669744451744)
- [View post](https://x.com/vidstige81/status/1837030038899667256)
- [View post](https://x.com/rauchg/status/1834763888640114983)
- [View post](https://x.com/ConveLab/status/1829319248348401898)
- [View post](https://x.com/YutongLiang_/status/1824702706675749349)
- [View post](https://x.com/raghavaupp/status/1823910917781745716)
- [View post](https://x.com/PeterMitrano/status/1823744492215632022)
- [View post](https://x.com/Parvkpr/status/1815507533542592695)
- [View post](https://x.com/heyellieday/status/1808936004105220390)
- [View post](https://x.com/YongkieWiyogo/status/1770334611127648271)
- [View post](https://x.com/raghavaupp/status/1769201746016911455)
- [View post](https://x.com/changh95/status/1767940833666564376)
- [View post](https://x.com/LvZhaoyang/status/1760702082800287917)
- [View post](https://x.com/goodguyguybrush/status/1758277525904449725)
- [View post](https://x.com/degentr0py/status/1728075963445977269)
- [View post](https://x.com/rauchg/status/1710085538836025818)
- [View post](https://x.com/steventey/status/1710316611851497879)
## Start building today
Build, understand, and improve your data loop on one set of primitives, from your first recording to massive scale. Start with the SDK, or explore Rerun Hub.
- [Install the SDK](/docs/getting-started/quick-start)
- [Explore Rerun Hub](/hub)